Advancing the frontier of generally capable robotics
Tutor is a frontier research lab that trains foundation models for intelligent dexterous robot manipulation. At Tutor, we believe robotics will only be solved through the unification of research and deployment.
Our approach
Learned robot manipulation is a function of data in
Robotics is a no-free-lunch full-stack problem
The deployment flywheel
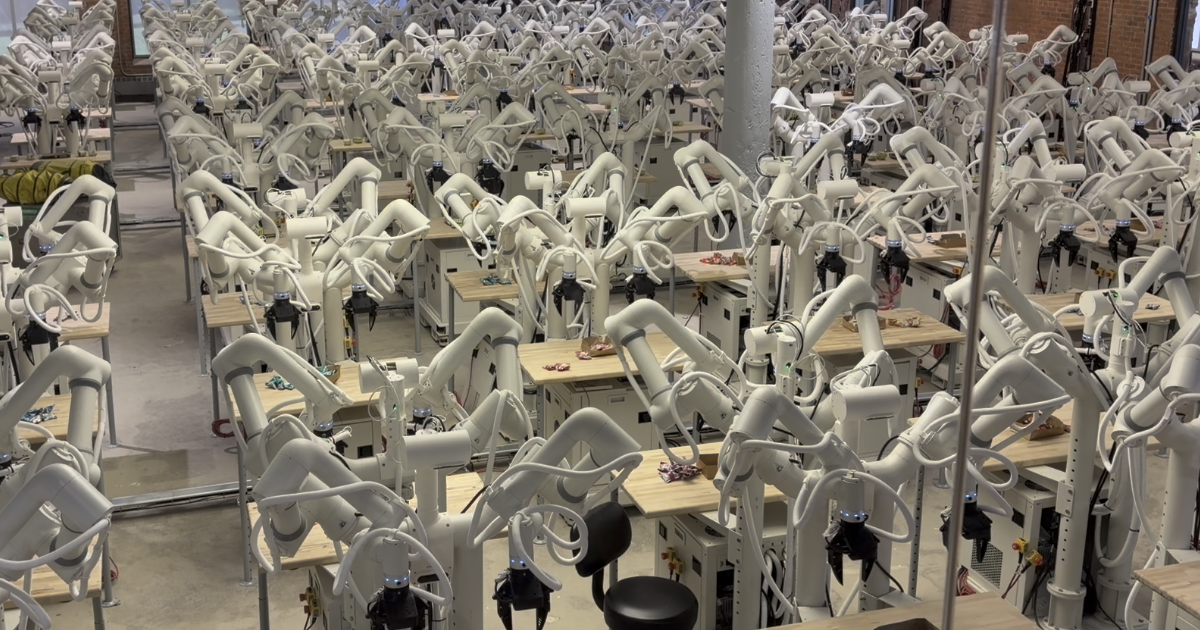
Data Factory 1 (DF1)

Learning from Tutor demonstration
Our Tutors teleoperate robots through new tasks to demonstrate robot behaviors for initial behavior cloning.
Corrections from robots' own mistakes
Teleoperators not only perform initial task demonstrations but also correct mistakes and intervene when robots encounter errors, providing valuable data for model training.
Reward from Tutor feedback
Episodes of robot rollouts are scored by our Tutors to provide positive or negative feedback on the robot's behavior, providing signal for the post-training process to accentuate favorable robot behaviors and down-weight low-quality behaviors.
Research across the stack
Join the mission
Solving the hardest problems in robotics requires passionate, creative, and dedicated minds. If that sounds like you, get in touch.